
Try the tuner.
Detune the capacitors, then let coordinate descent find the match.
Automated
Impedance Matcher
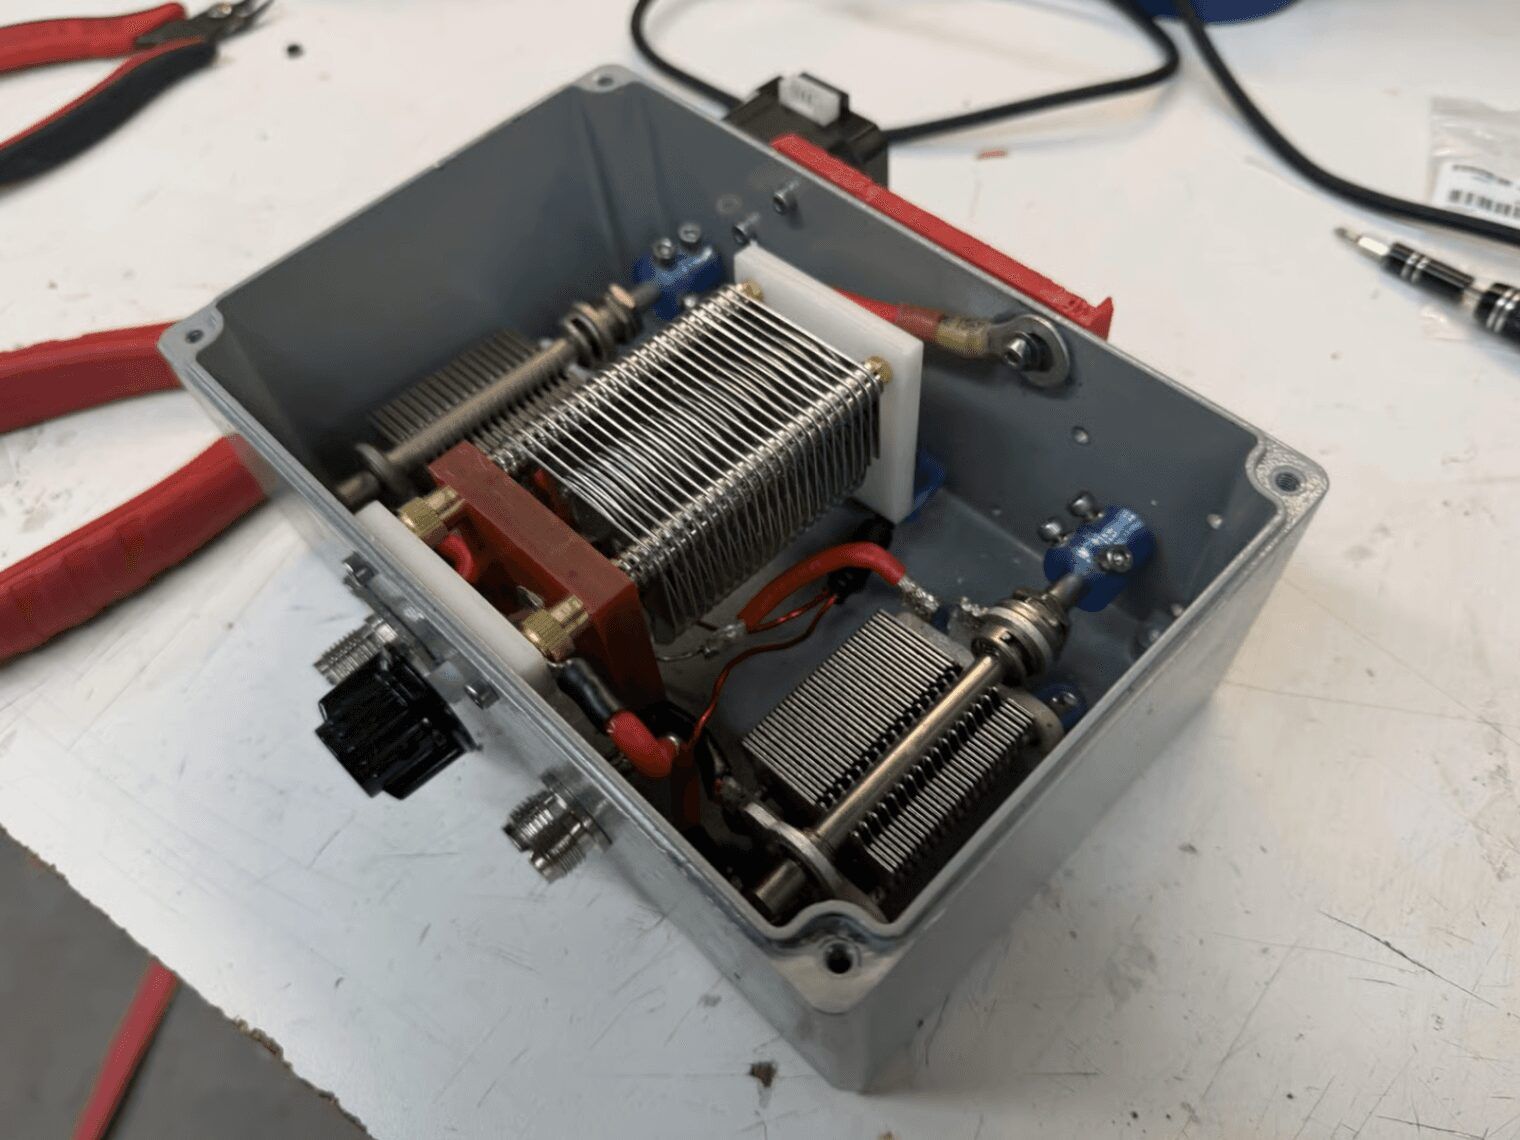
A closed-loop RF matcher that tunes two motor-driven capacitors as plasma conditions change.
- Deployed match
- ~1.2 VSWR
- Forward power
- 95 W
- Build cost
- $636
Inspect the mechanism, or detune the match and run auto-tuning.
Air-variable capacitors
Turning the two motor-driven air-variable capacitors changes the RF network. The plate overlap changes capacitance; the controller searches both axes for lower reflected power.
500 V air-variable capacitors
T-network · ~2 µH coil
Stepper motors
Two stepper motors turn the capacitor shafts. Microstepping lets the firmware make small corrections as the chamber’s impedance drifts.
0.9° NEMA 17 steppers
1/64 microstepping
Closed-loop control
A Teensy 4.1 and custom control PCB read forward and reverse power, then command the motors. The OLED and encoder provide local control.
Teensy 4.1 · custom two-layer PCB
I2C OLED · rotary encoder
Select a component to follow its role in the loop.
Move either capacitor to detune the match, then run auto-tuning. Watch the controller search for lower reflected power.

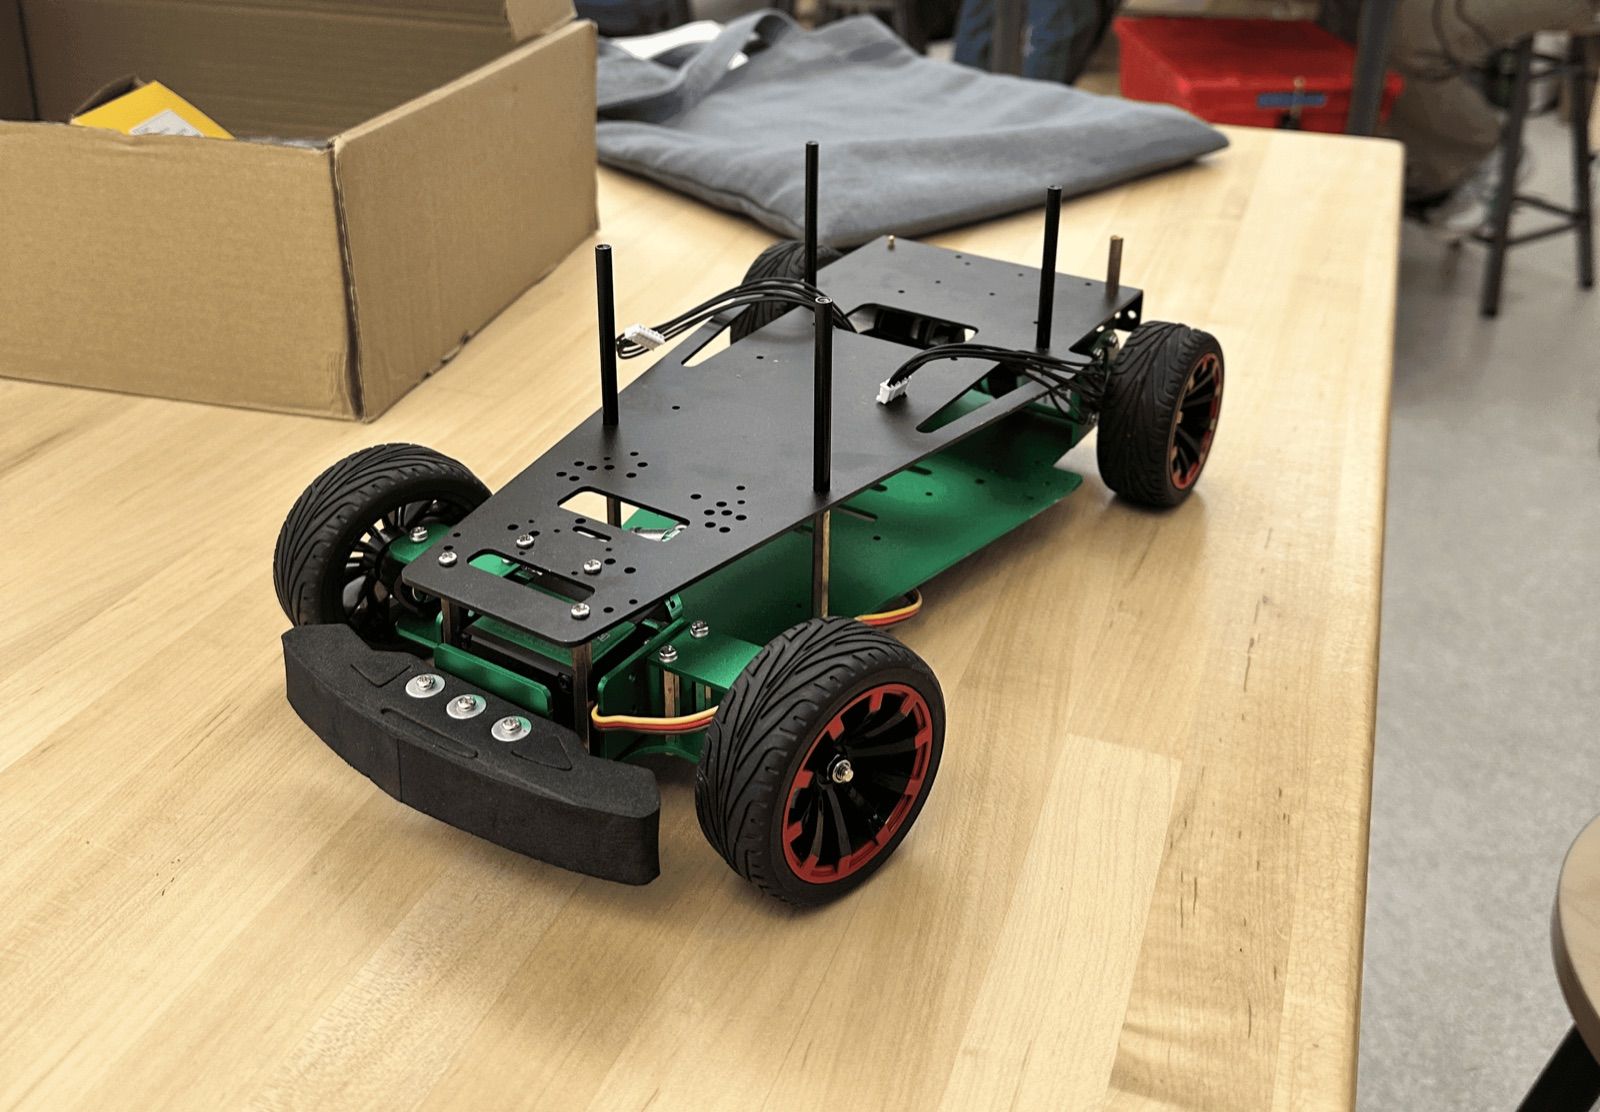
Real-Time Embedded Vehicle
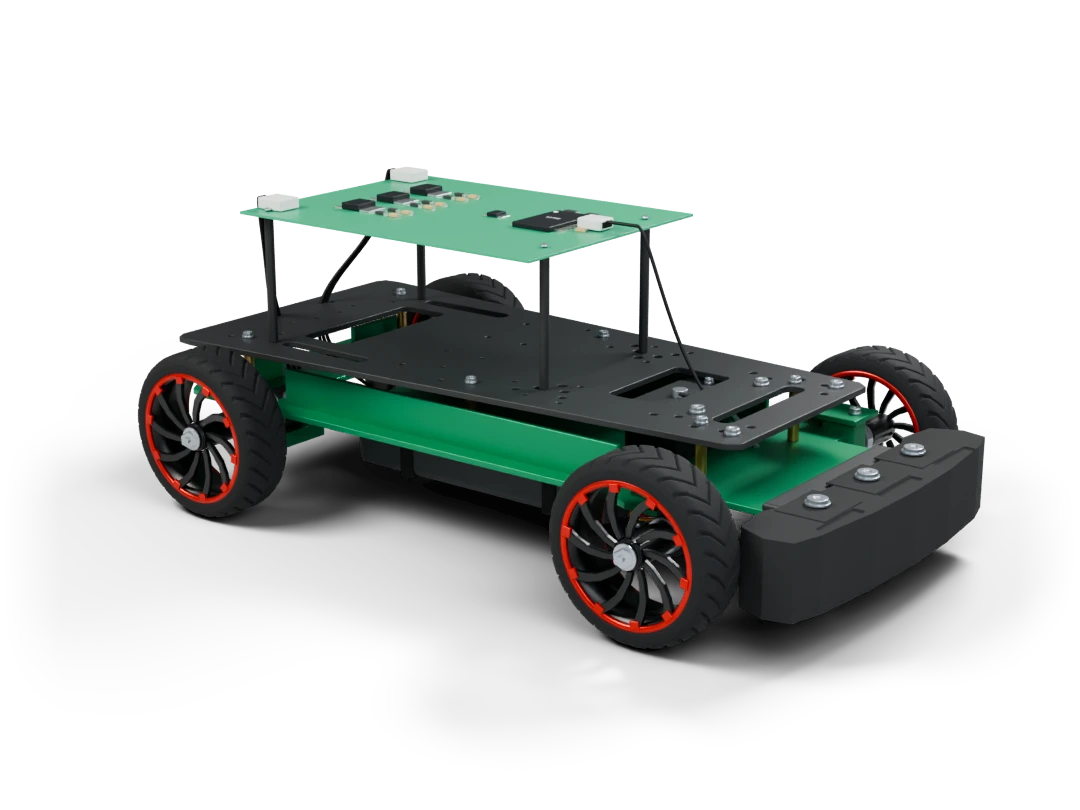
An embedded vehicle with a custom preemptive RTOS, carrier PCB, and PID motor control.
- Project result
- STM32 Cortex-M4
- Project result
- RMS scheduler
- Project result
- <10% average speed error

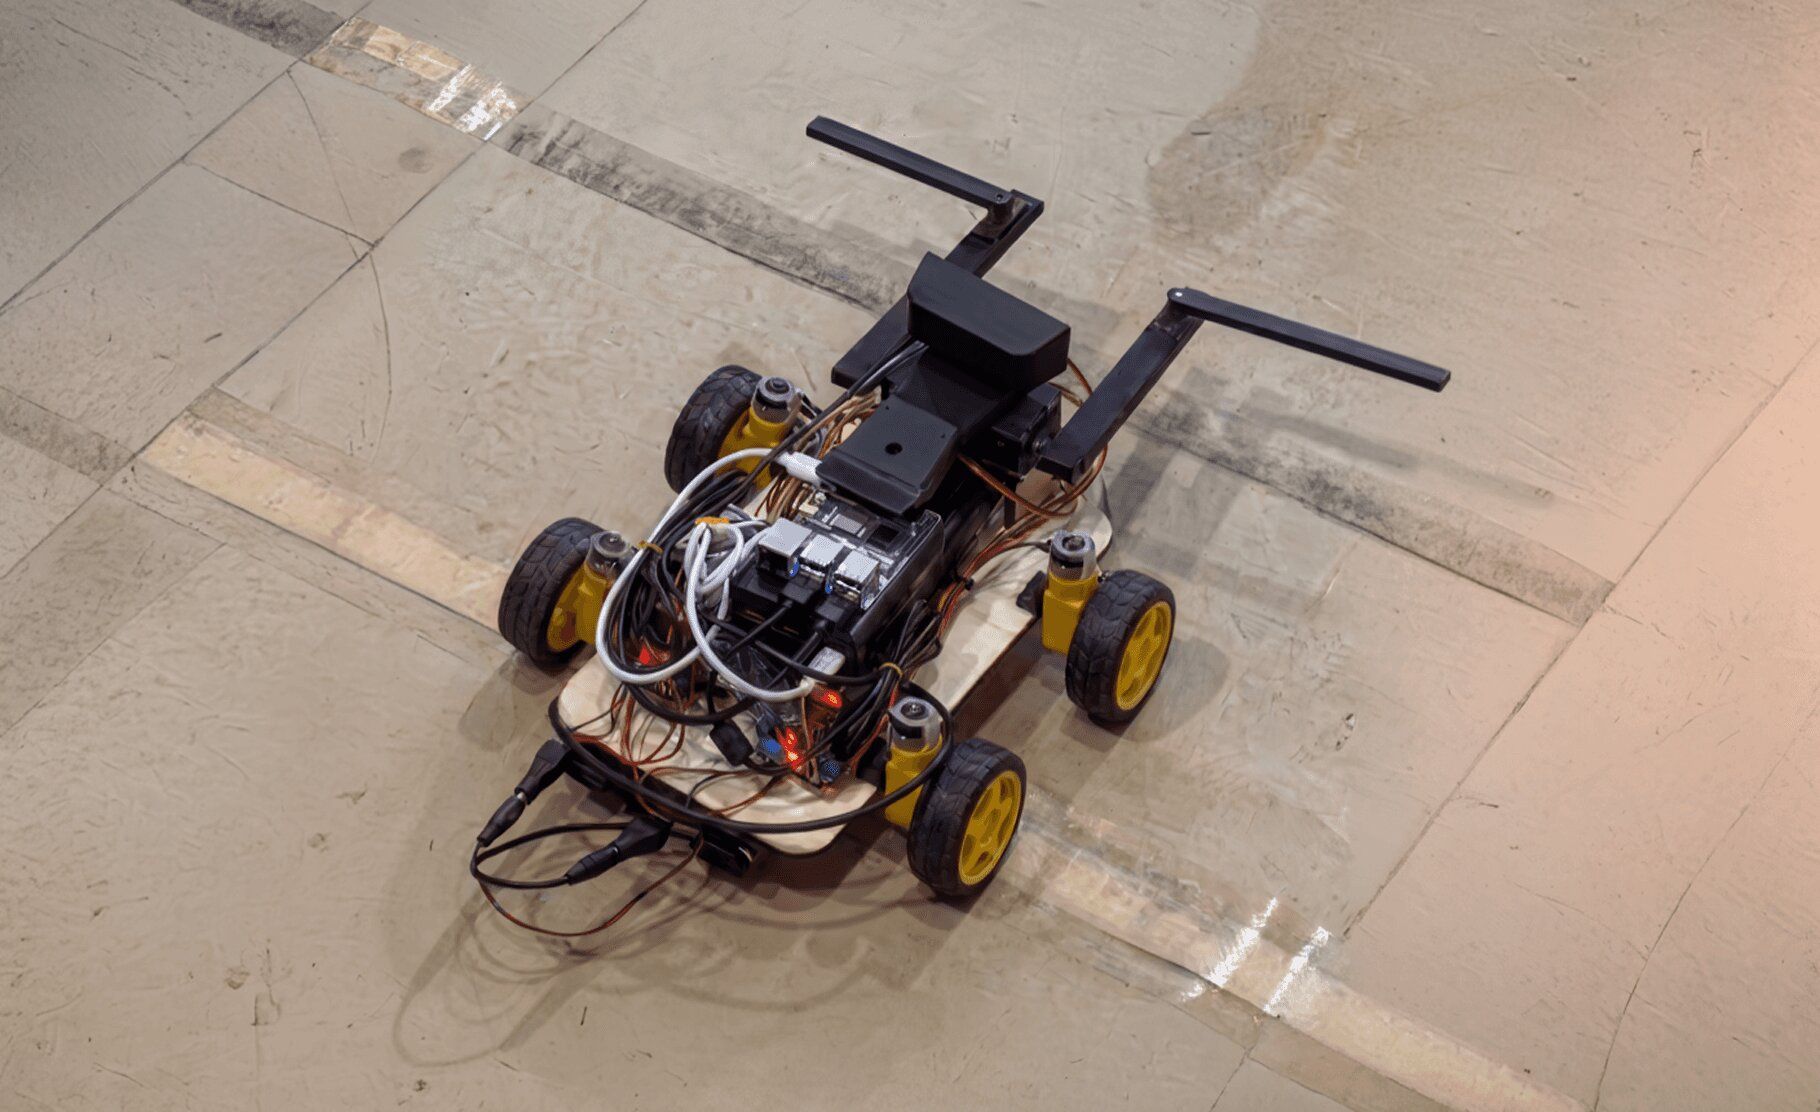
Trash Collection Robot
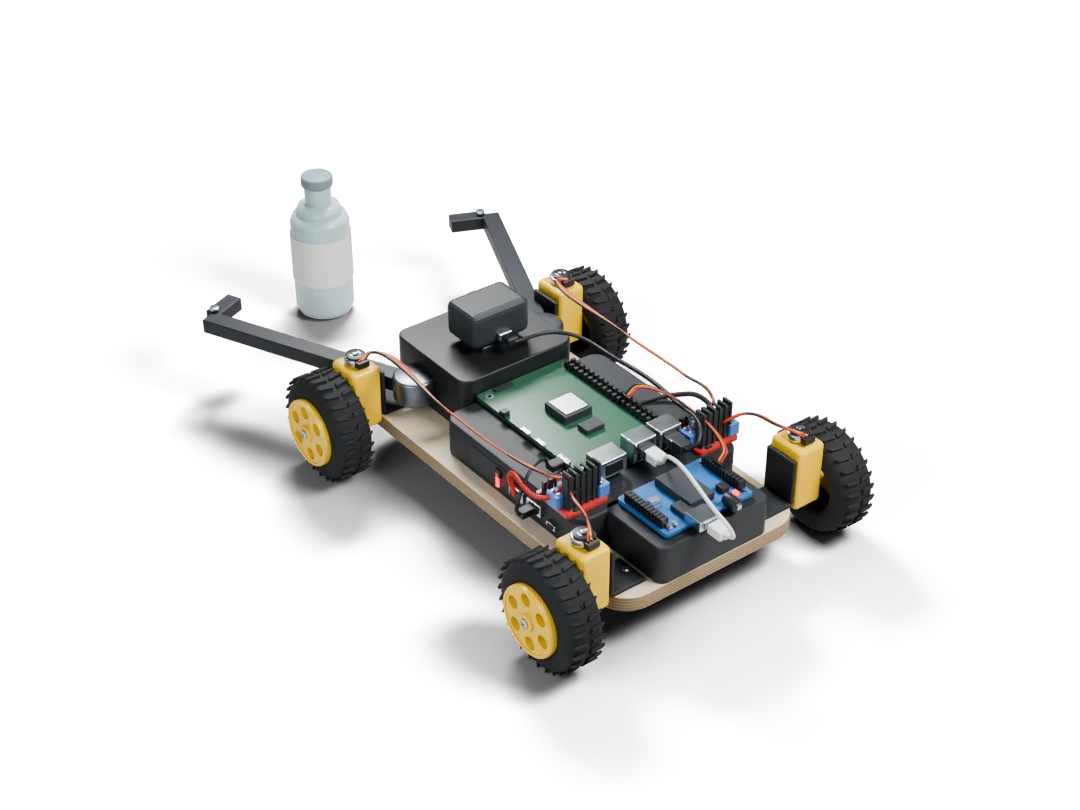
An autonomous bottle-collection robot with computer vision, motor control, and custom power delivery.
- Project result
- Raspberry Pi CV
- Project result
- Arduino control
- Project result
- 9V quad H-bridge